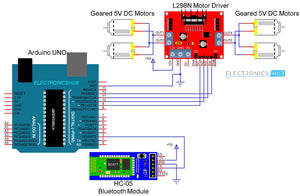
Components Of Making Bluetooth Controlled Robot Using Arduino Just component - an Arduino Uno, L298N motor driver, HC-05 module, and motors.
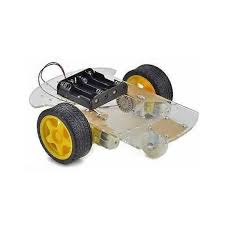
Components Of Making Bluetooth Controlled Robot Using Arduino Just component - a clear acrylic robot chassis with two yellow wheels and a battery holder.
Components Of Making Bluetooth Controlled Robot Using Arduino Just component - an Arduino Uno, L298N motor driver, HC-05 module, and motors.
Components Of Making Bluetooth Controlled Robot Using Arduino Just component - a clear acrylic robot chassis with two yellow wheels and a battery holder.

Components Of Making Bluetooth Controlled Robot Using Arduino Just component

Sale price Rs 5,550
SKU: New
Log in to use Wishlist
Add to Compare

Pickup available at Digilog Electronics

Usually ready in 2 hours

Components Of Making Bluetooth Controlled Robot Using Arduino Just component - an Arduino Uno, L298N motor driver, HC-05 module, and motors.

Components Of Making Bluetooth Controlled Robot Using Arduino Just component

  • Digilog Electronics

    Pickup available, usually ready in 2 hours

    🏢 Digilog Electronics 13th the RegalStreet,
    Back side of KFC, Near Abubakar Masjid Mall Road
    Lahore
    Pakistan

    +923124002221

    Check this on google map

This kit provides the essential components required to build a Bluetooth-controlled robot using an Arduino platform. It includes the core hardware necessary for motor control, wireless communication, and structural assembly.

Components included:

  • Arduino UNO
  • L298N Motor Driver Module
  • HC-05 Bluetooth Module
  • Robot Chassis
  • Connecting Wires
  • Battery Pack

The Arduino UNO is a microcontroller board based on the ATmega328P, designed to serve as the central processing unit for electronic projects. The L298N motor driver module is a high-voltage, high-current dual full-bridge driver designed to accept standard TTL logic levels and drive inductive loads such as DC motors. The HC-05 module is a Bluetooth serial port protocol module used for wireless data communication between the robot and a controller device.